05 · Hardware · Mechatronics
Ball-Launching Arm
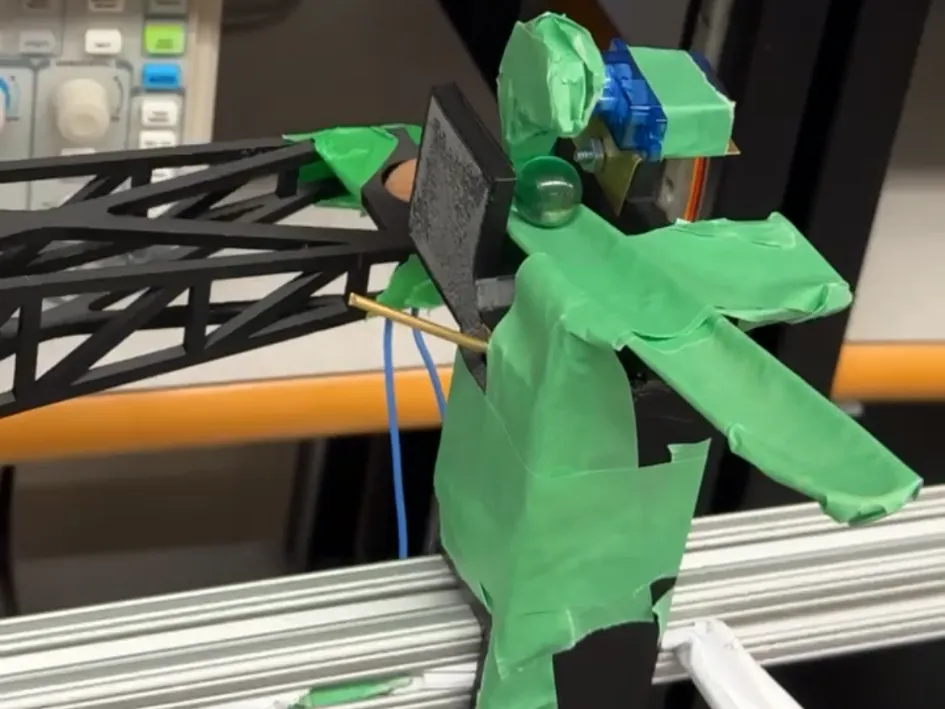
An autonomous arm that senses which of three balls is loaded, feeds one at a time, and launches or drops it. I led the control system.
Controls lead · May – Aug 2025
05 · Hardware · Mechatronics
An autonomous arm that senses which of three balls is loaded, feeds one at a time, and launches or drops it. I led the control system.
Controls lead · May – Aug 2025
Every subsystem met its design constraints in testing.
On the black arm the light sensor needed steady light and missed the marble. We moved it to the hopper with a white LED opposite, so room light no longer changed the readings.
The sensor could not see the translucent marble at all. The hopper's brass rods are spaced so the marble falls through and is dropped, and the sensor only tells wood from fluffy.
Simulink's trapezoidal trajectory block reached a forward target and never came back. My own generator moved the arm in both directions without overshoot.
The hopper servo idles at 90°, pushes to 120° for 0.5 s, then ignores the sensor for 15 s, so a second ball cannot follow before the launch ends.
Three truss designs went through FEA. A matrix of six weighted criteria (deflection, inertia, mass, and more) chose the third: 2.75 points against 2.0 and 1.4.
An ESP32-S3 wearable with IMU and heart-rate sensing and an on-device activity classifier that streams to a phone over BLE, with no cloud.